2024 · Lead Mechanical
Shooter Design & Autonomous
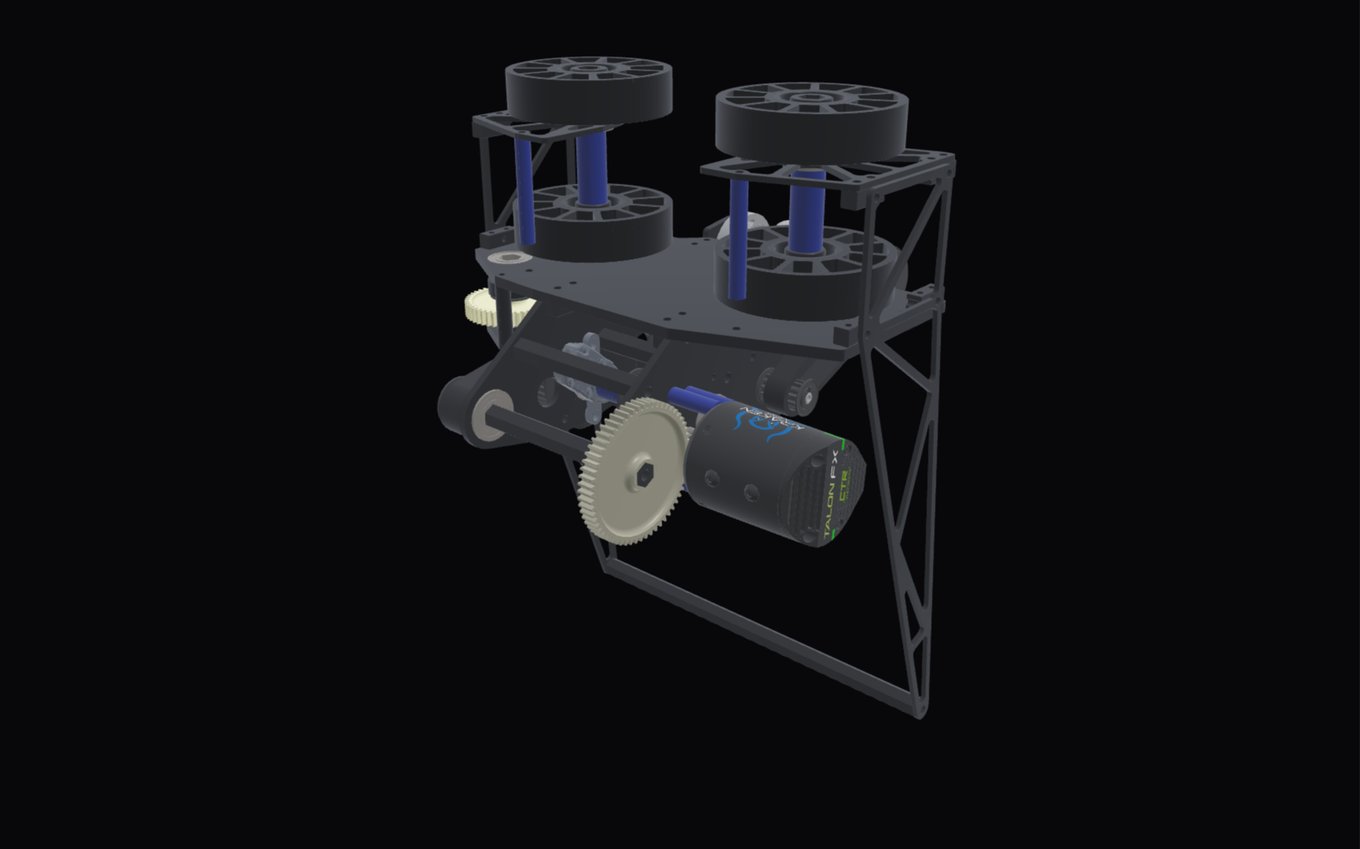
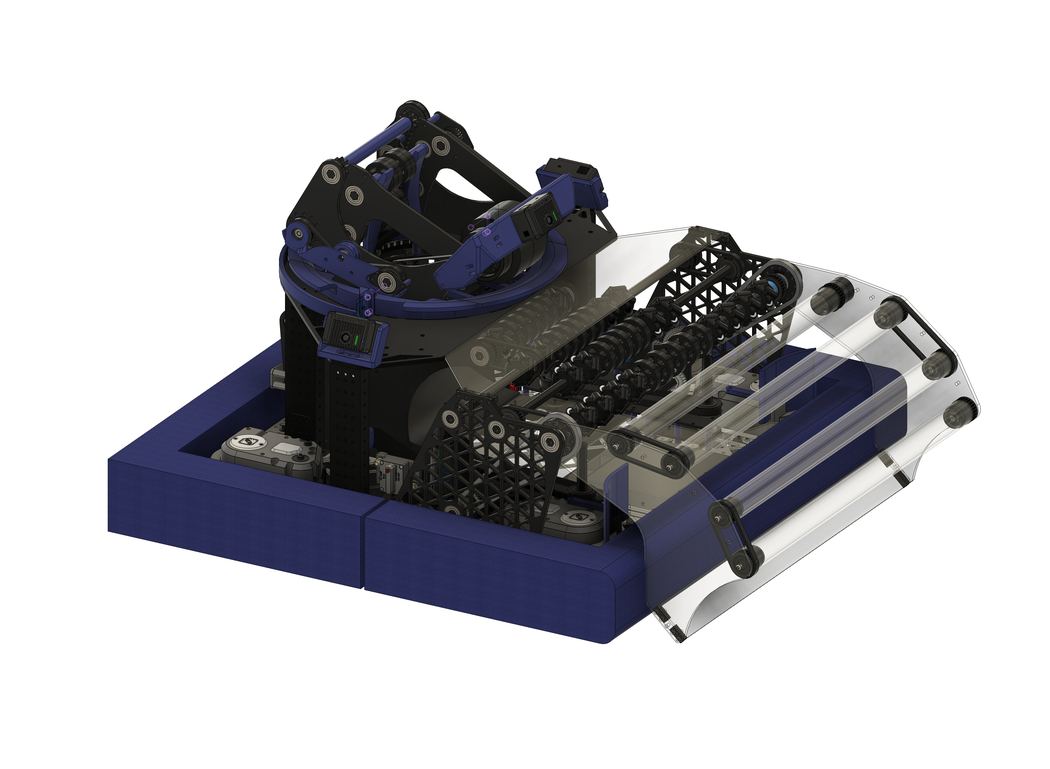
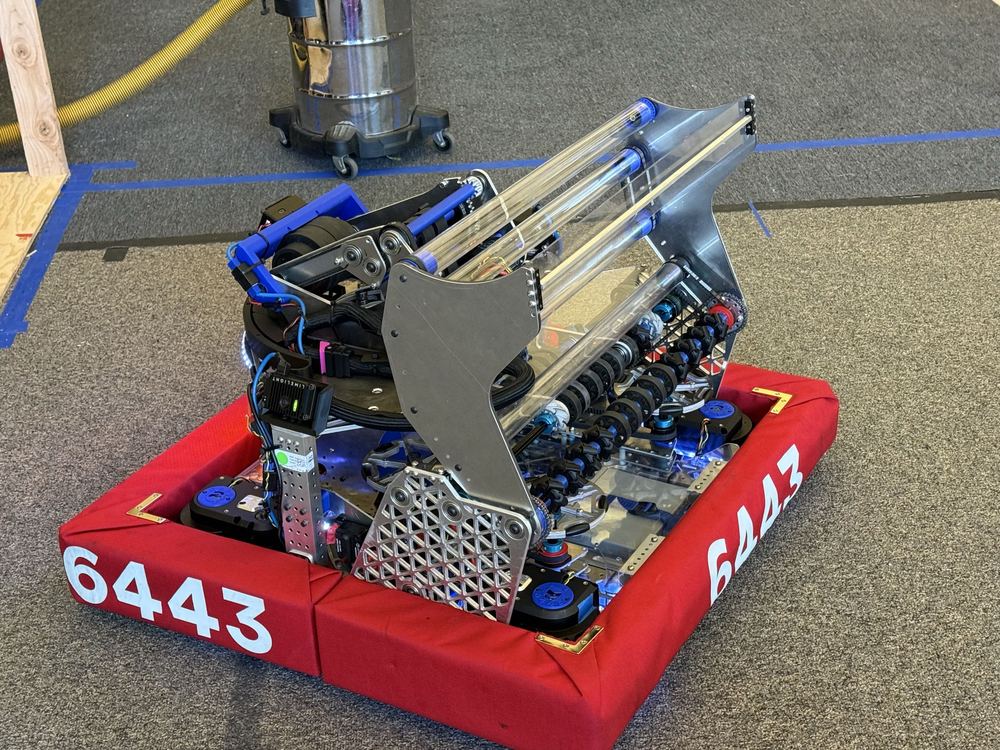
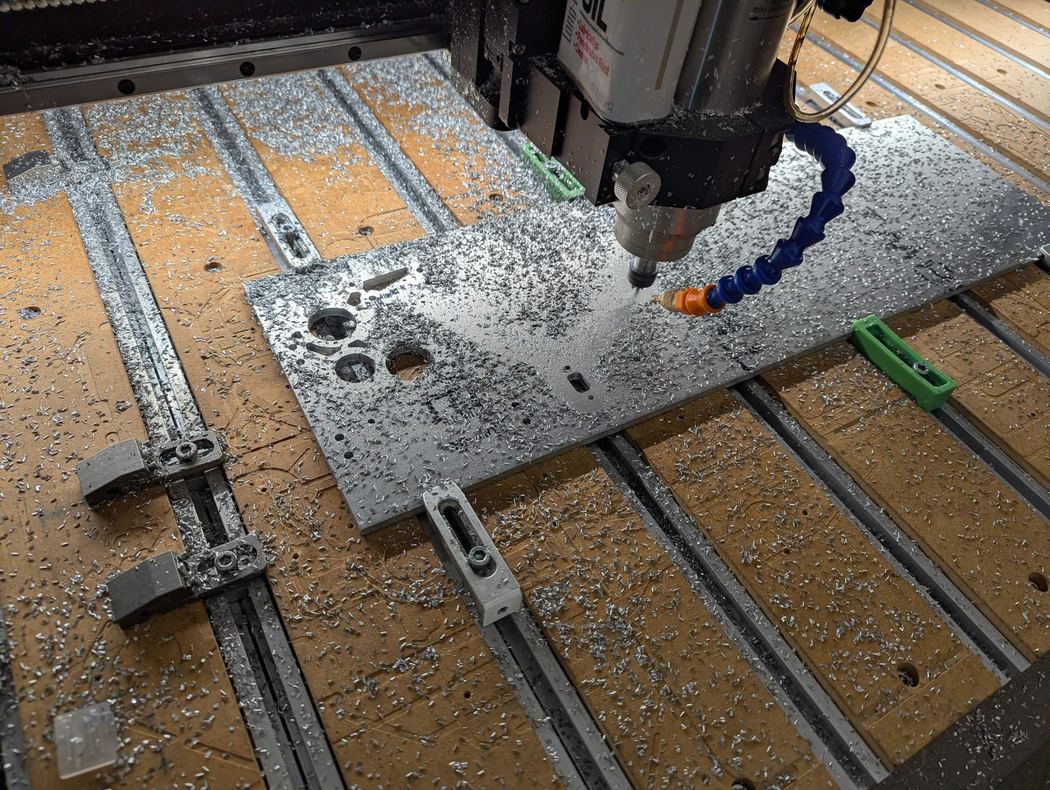
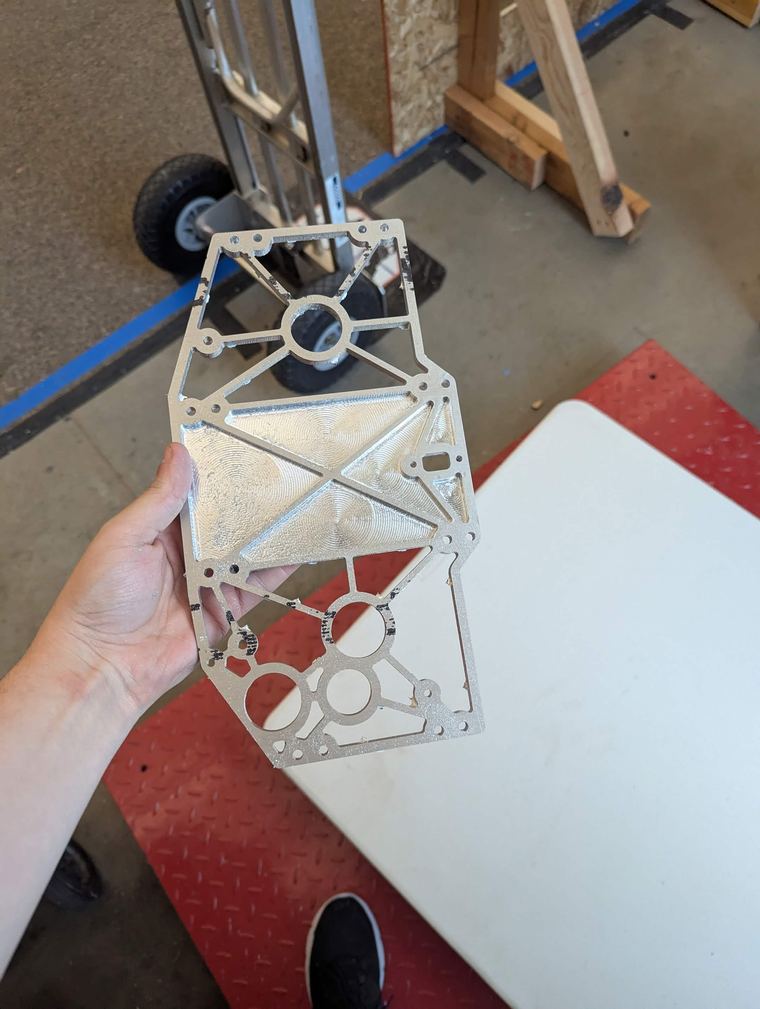
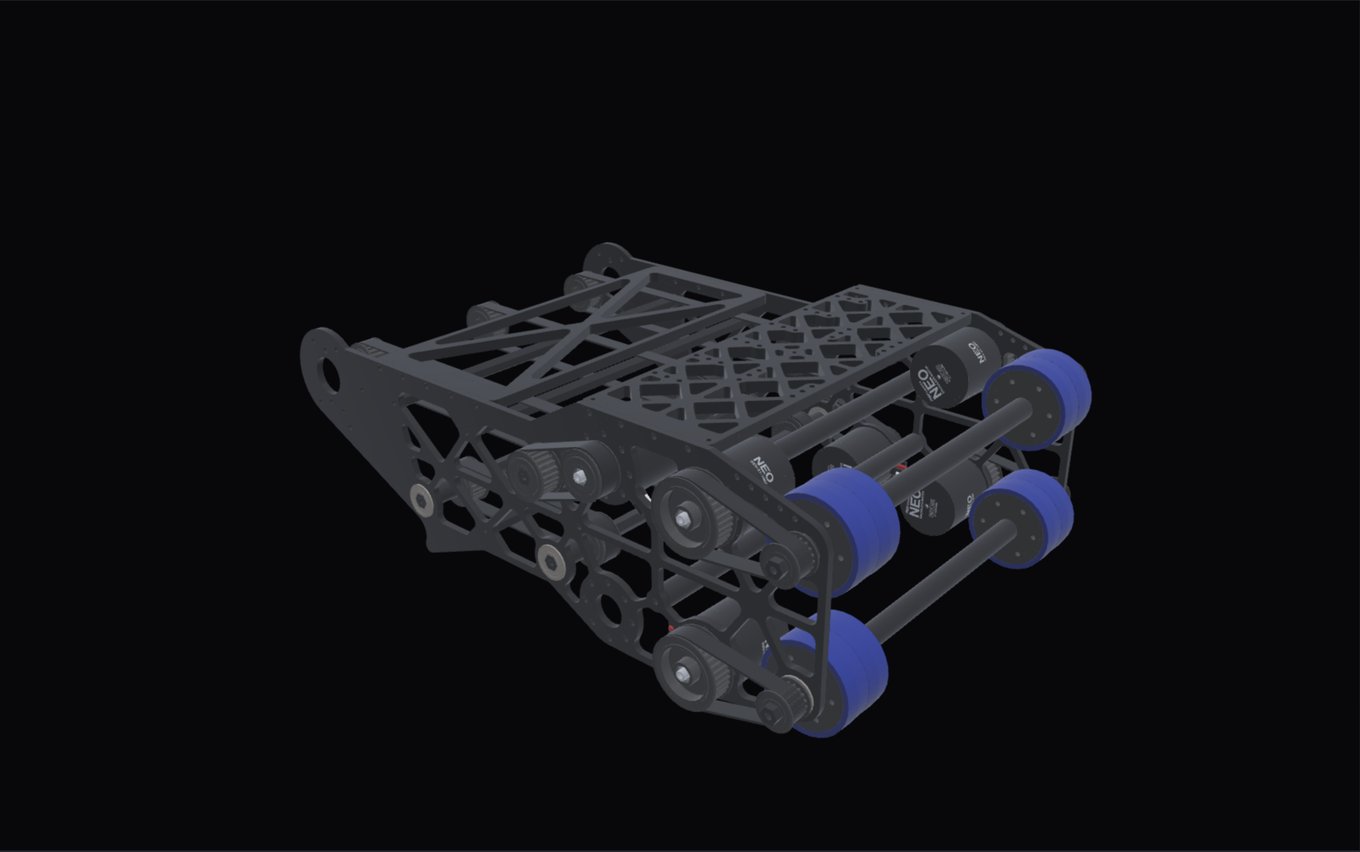
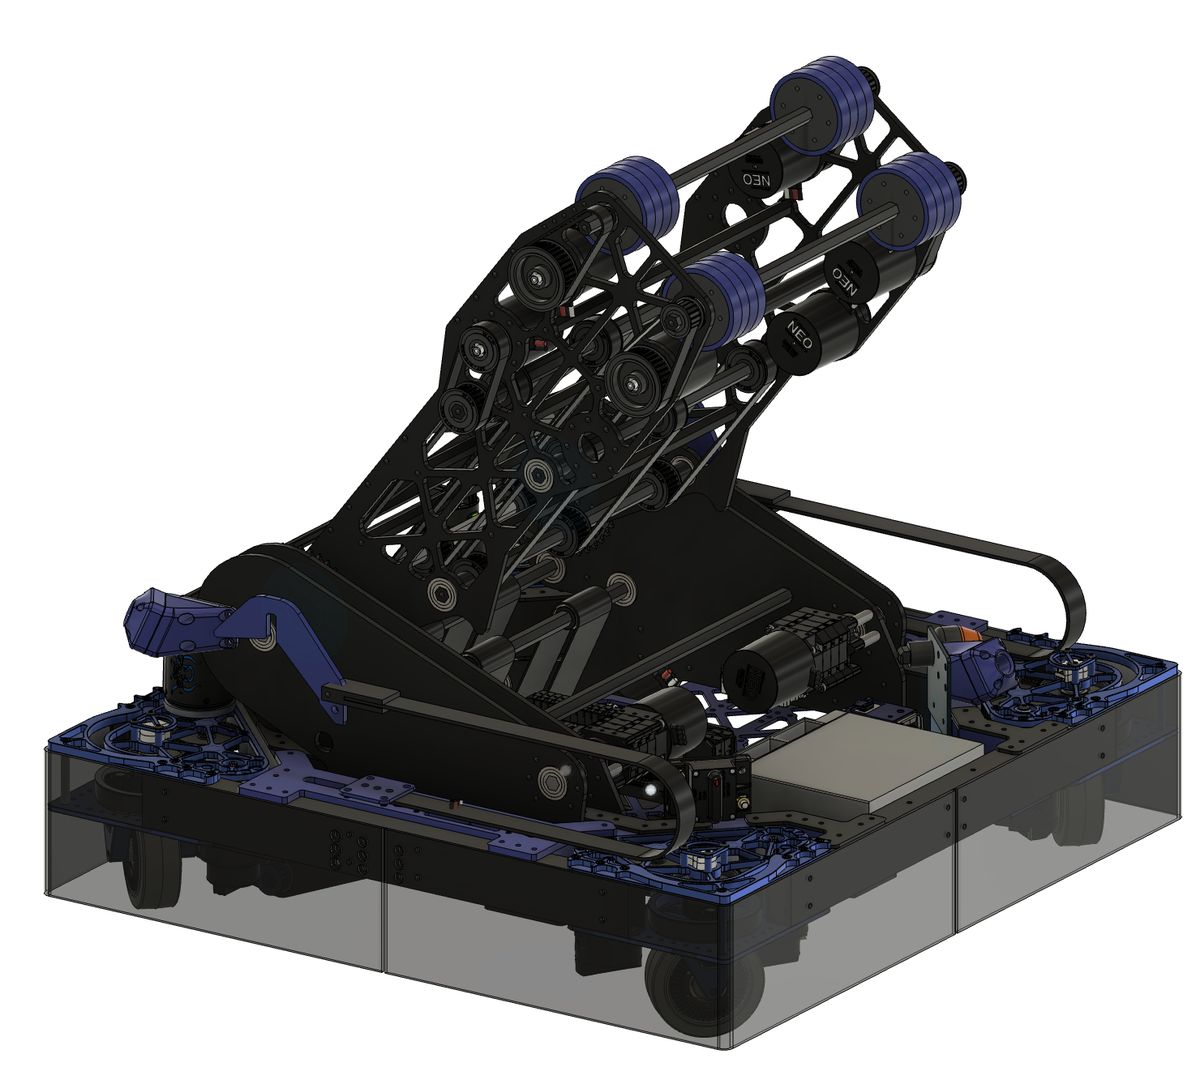
In 2024, my responsibility included the full shooter subsystem, design and manufacturing. I designed the shooter to be easy to manufacture using our sponsors waterjets and off the shelf components. There was little room for revision due to the tight schedule, causing the project to rely heavily on early prototyping and simulations
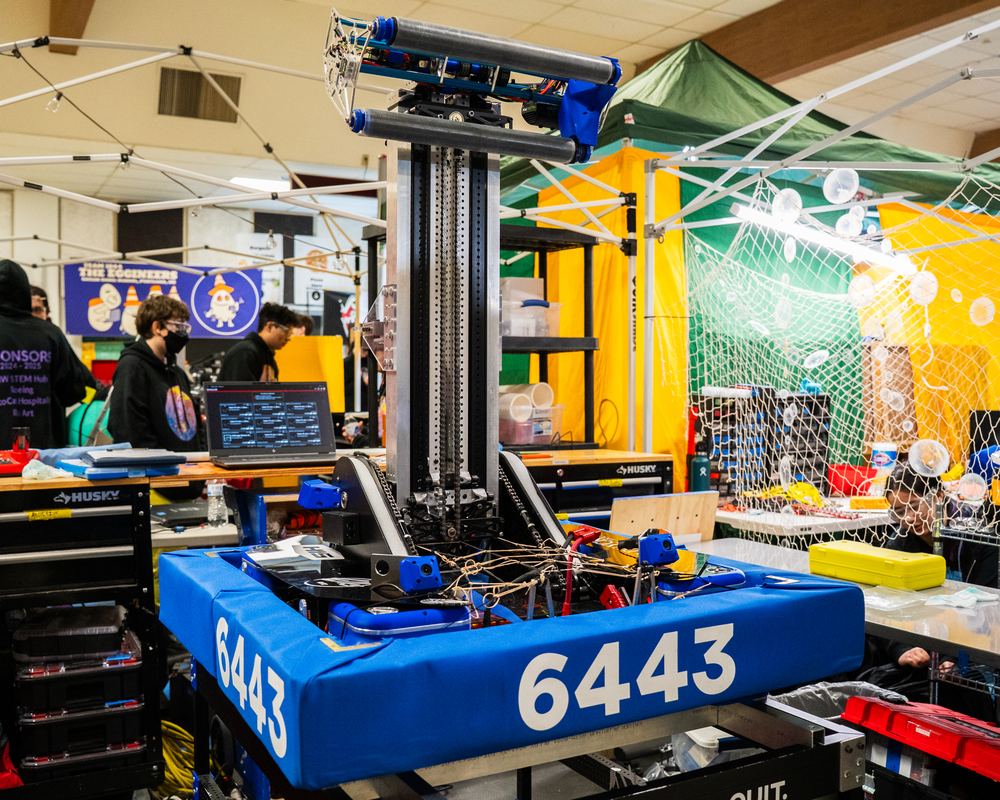
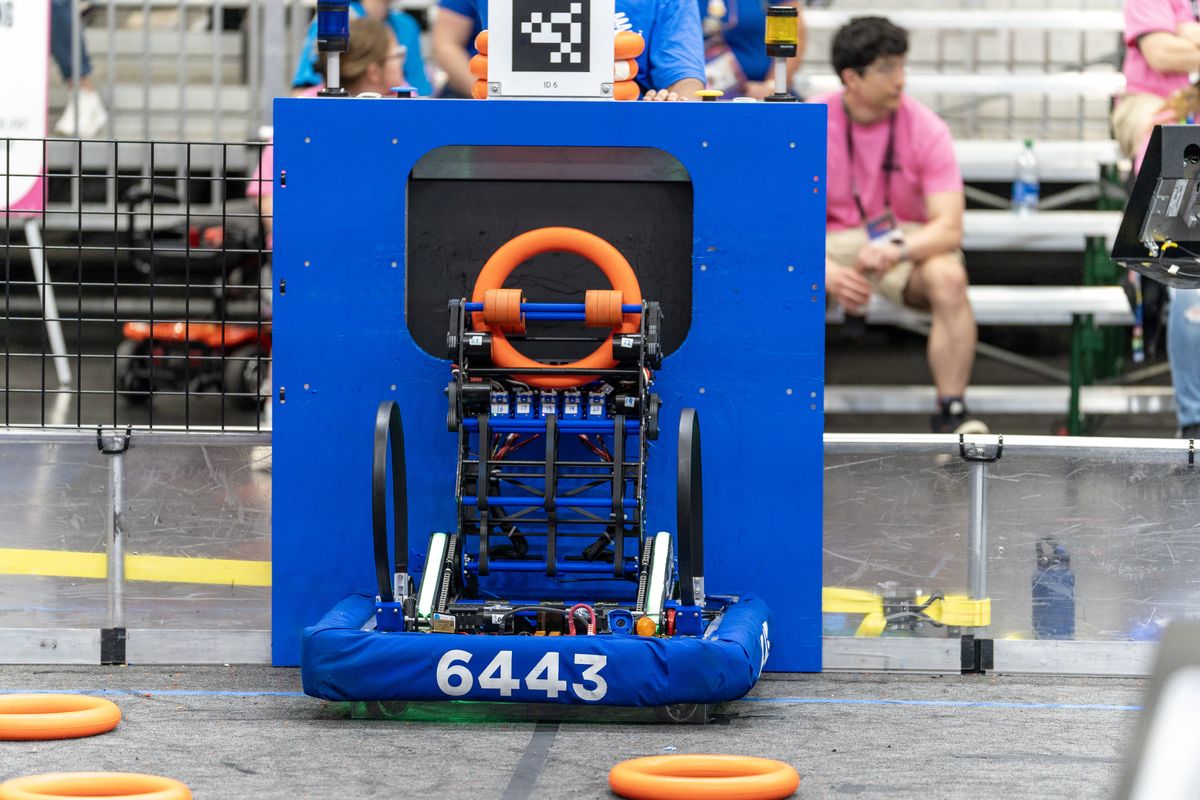
The shooter used an offset-wheel mechanism I developed to handle two targets with one system. Offsetting the wheels puts spin on the game piece at high RPM to reach the far target, while holding enough control at low RPM to place into the near one. It is not in the CAD above; it appears in the photos of the built robot.
I also helped write the robot's autonomous routines and planned the routes and strategy behind them, contributing to our team's Autonomous Award at the World Championship. The season became the team's most successful, with five event wins, including the Pacific Northwest District Championship, and a fourth-place finish in our Worlds division as an alliance captain.
- Scope
- Full shooter mechanism · Autonomous programming and strategy
- Build timeline
- Four weeks
- Shooter
- 4 in flywheels · 8,000 RPM · offset-wheel spin control
- Robot weight
- 124 lb against a 125 lb limit
- Drivetrain
- SDS MK4 swerve, L3+ ratio · Kraken drive, Falcon steer · 20 motors total
- Stock
- 6061 aluminium plate · 0.125, 0.25 and 0.375 in
- Parts drawn
- 50+ unique
- Season results
- Five event wins · PNW District Champions
- World Championship
- Autonomous Award · Fourth in division as alliance captain
- Record
- thebluealliance.com/team/6443/2024